
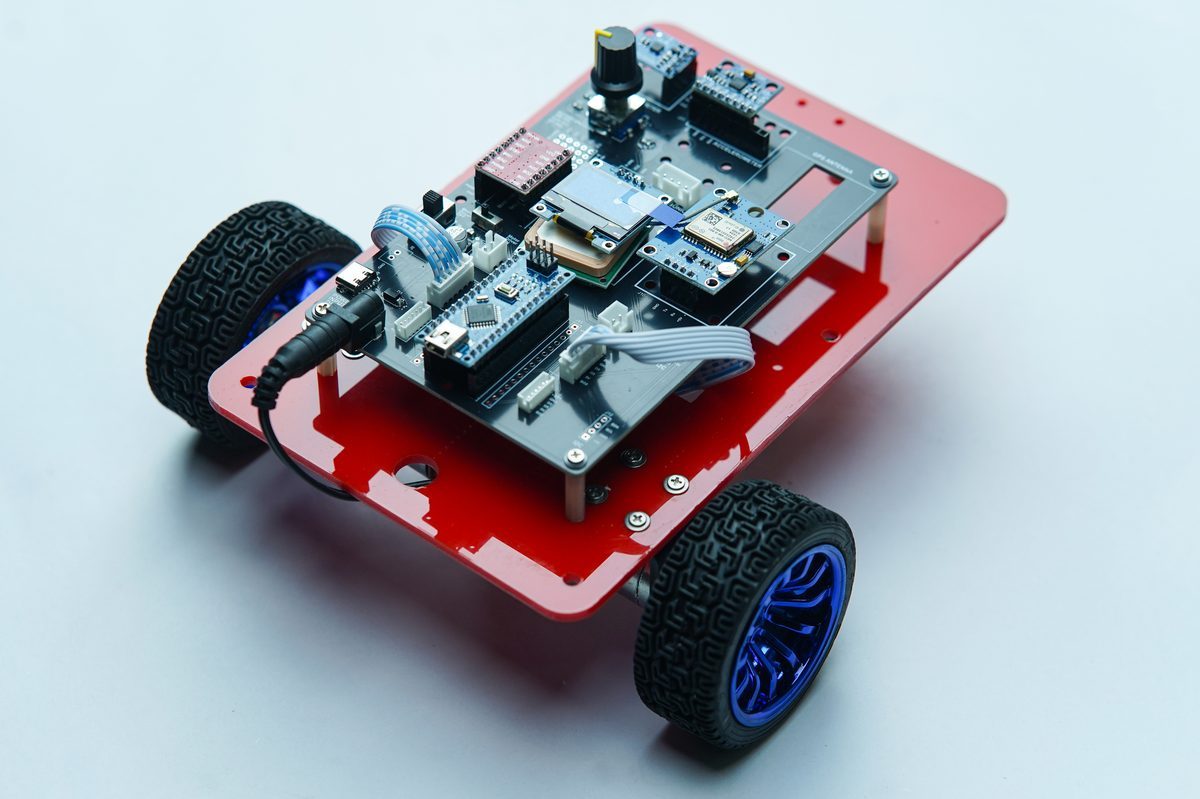
Robot Odometry
Build kinematics, wheel odometry and sensor fusion on ZAS Car-3 through live bench experiments and a robot navigation capstone.
University / undergraduateView course : Robot Odometry
Robotics
Explore camera-based motion estimation, visual mapping and spatial understanding for autonomous navigation.
Explore camera-based motion estimation, visual mapping and spatial understanding for autonomous navigation. This course is part of the planned ZAS Robotics collection. Detailed learning content will be developed in a later phase.
A journey video is available below. The detailed syllabus, training duration and delivery format will be added when the visual-navigation course materials are supplied.
Learning outcomes will be added with the course content.
Industry skills will be defined with the detailed syllabus.
Relevant industry roles will be added when the course scope is confirmed.
The detailed syllabus will be added when this course enters development.
Explore the robot, course introduction and demonstrations below.
KEEP EXPLORING
Build kinematics, wheel odometry and sensor fusion on ZAS Car-3 through live bench experiments and a robot navigation capstone.
Build an autonomous navigation stack on ZAS Car-5: encoder motor control, ROS2 communication, odometry, LiDAR, SLAM and Nav2.
Explore spatial intelligence and vision-language-action concepts for the next generation of robotic systems.