
ROS2 – LiDAR / SLAM / Nav2
Build an autonomous navigation stack on ZAS Car-5: encoder motor control, ROS2 communication, odometry, LiDAR, SLAM and Nav2.
University / engineering collegeView course : ROS2 – LiDAR / SLAM / Nav2
Robotics
Build kinematics, wheel odometry and sensor fusion on ZAS Car-3 through live bench experiments and a robot navigation capstone.
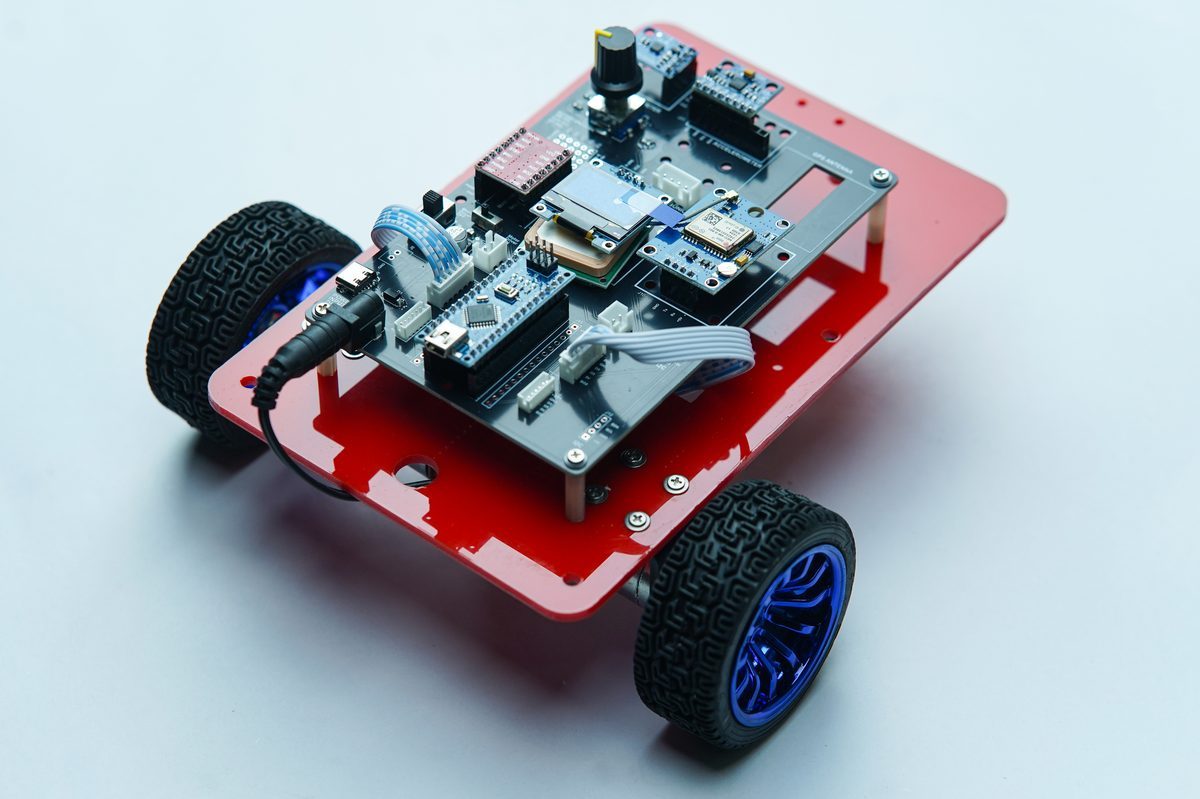
A university-level, hands-on robotics course built around ZAS Car-3. Each module connects a concept to a demonstration on the same robot: measure wheel motion, observe odometry drift, calibrate inertial and magnetic sensors, tune filters and compare dead reckoning with a fused pose estimate. Six core bench sessions culminate in a waypoint-following race, with a bonus particle-filter localisation exercise.
Six core modules plus one bonus module. Each session includes a physical robot demonstration. Training dates and enrolment details will be confirmed separately.
Related role examples inferred from the skills covered; these are not job-placement claims.
Each stage combines concepts with a hands-on demonstration on the robot.
Command a 1 m straight drive and a 90-degree pivot; compare measured and commanded motion and tune the wheel-base constant.
Drive a taped 1 m square open-loop, plot the odometry trail and observe the failure to close.
Spin the robot in place for 60 seconds and observe gyro-only heading drift in real time.
Perform a live figure-eight calibration and compare raw and calibrated heading on the OLED.
Tune the blend weight through serial input and compare the fused trace with both raw inputs.
Race a dead-reckoning-only robot against an EKF-fused robot on the same square course from the same start line.
Place the robot at an unknown start in a taped rectangular pen and observe the particle cloud converge as it drives and takes range readings.
Explore the robot, course introduction and demonstrations below.
KEEP EXPLORING
Build an autonomous navigation stack on ZAS Car-5: encoder motor control, ROS2 communication, odometry, LiDAR, SLAM and Nav2.
Explore camera-based motion estimation, visual mapping and spatial understanding for autonomous navigation.
Explore spatial intelligence and vision-language-action concepts for the next generation of robotic systems.